Hi, I'm Narendra. My passion is building Embodied Intelligence to elevate humanity. My research is currently focused on JEPA based World Models for long-horizon planning. I've also worked on Self-supervised Learning, Deep RL and theoretical Deep Learning. I'm an undergrad @ IIT Bombay.
Current Work
Hierarchical JEPA for long-horizon planning
Following LeCun's position paper to add a Systems-2 JEPA on top of existing WMs, to perform long-horizon tasks. Also design a scalable training method, for H-JEPA. Personal Project
Relevant Links
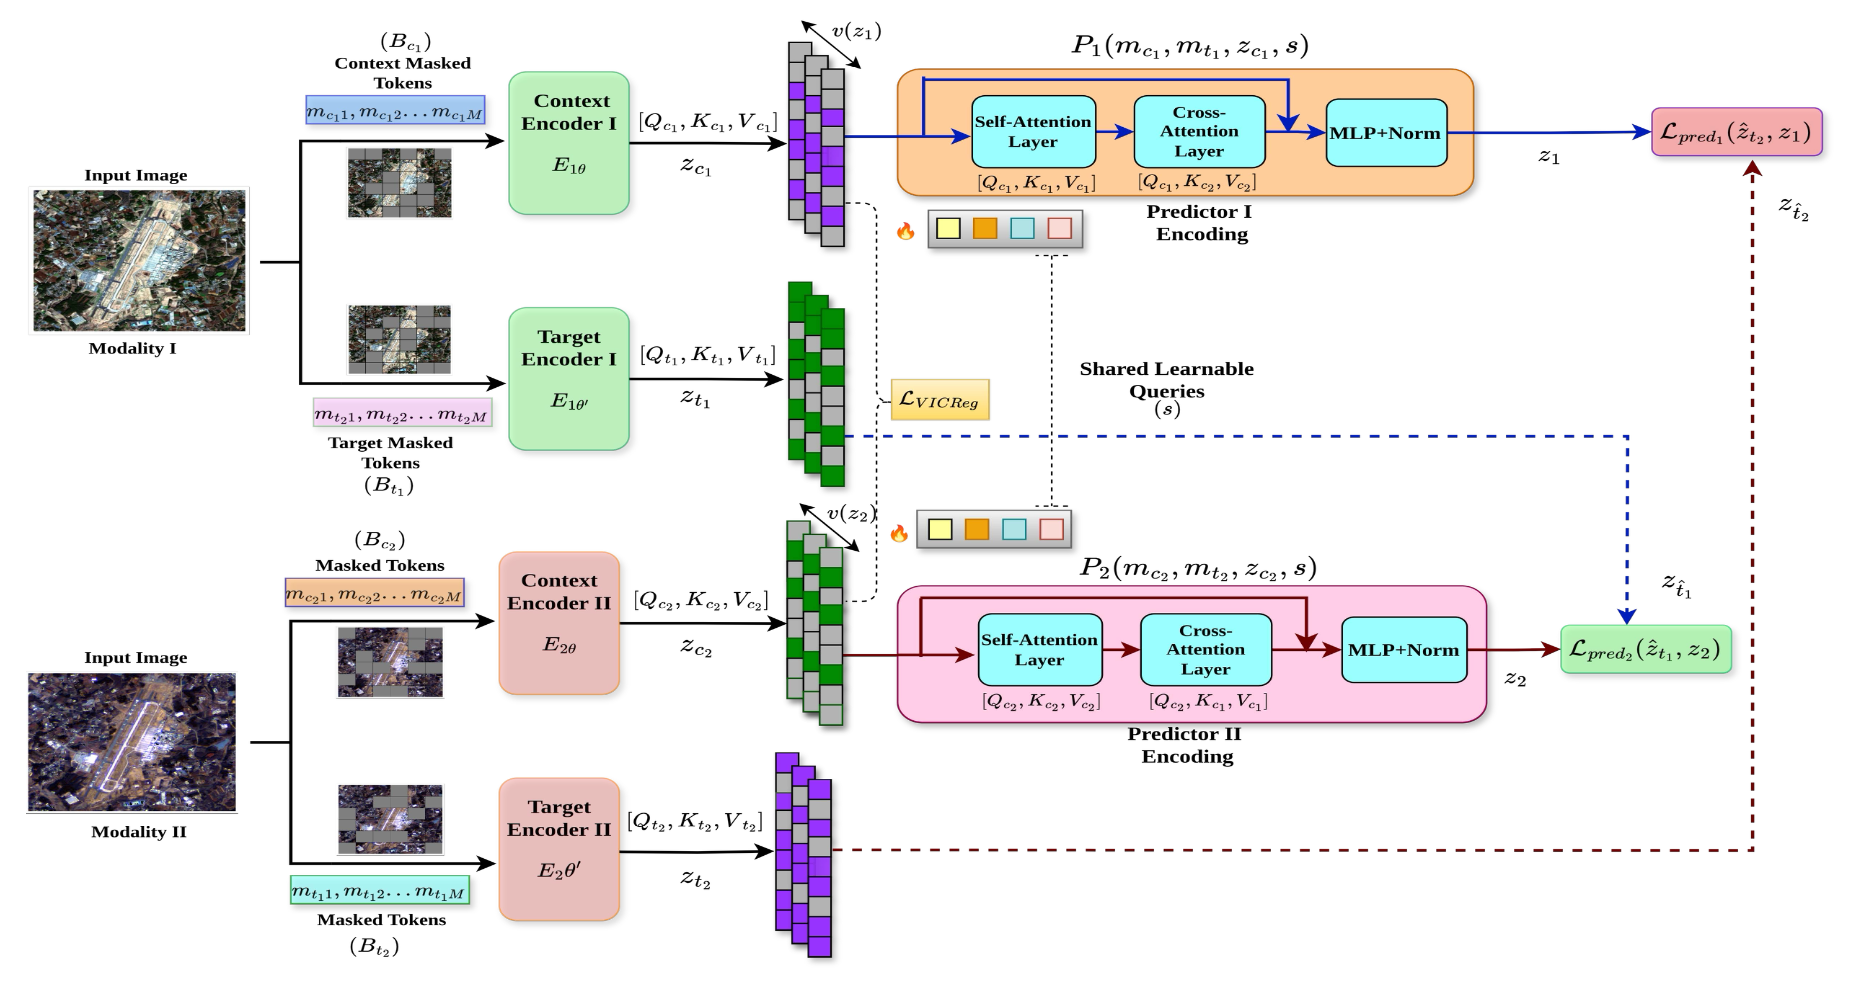
Cross-modal JEPA-based architecture, that beats SOTA on satellite image retrieval tasks, even with missing input modalities. Paper under review.
Versatile locomotion of a 6DoF biped in challenging terrain using an RL policy trained from scratch. Currently doing sim2real on a custom built biped.
A 3D Modelling and Animation engine like Blender, built from scratch in vanilla C++ and OpenGl. See the short clip created using my engine.
Trained on 500+ handpicked resumes, to suggest job profiles, future projects and optimize for ATS. 1000+ resumes analyzed in 1st week of going live.